Contact us for Pre-sales support,Bulk & wholesale orders via:
E-mail: microhello_sales@163.com
or via on-line chat app:
ID:+86 159 7819 3886
|
ID:weixinliang001
|
|
|
|
Overview
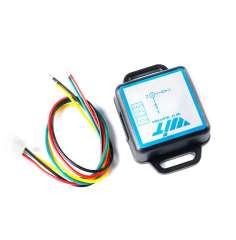
【Stable Data Output】------ 200Hz real time output of Euler angles (Roll, Pitch, Yaw), acceleration, angular velocity, quaternion.
【Robust Shell】------ Premium Aluminum housing + EMI immunity: 9~36V wide voltage input, ensuring stable operation in -40℃~85℃ harsh environments with anti-vibration optimization. TTL/232/485 Modbus interface optional .Plug-and-play connection for industrial projects and platform attitude measurement, reducing system integration complexity.
【Algorithm Advantage】------ 10-year R&D legacy: Proprietary dynamic fusion algorithm + Kalman filtering engine significantly reduces development cycles, achieving low-noise output and exceptional bias stability. Verified through deep collaboration with 350+ global projects and validated by 350K field-deployed devices, consistently delivering military-grade stable attitude data in industrial dynamic scenarios, empowering AGV precise navigation and motion control.
【Precision Calibration】------ Customized high-resolution turntable + self-developed algorithms: High-precision calibration system enhances measurement accuracy through advanced equipment and proprietary calibration techniques.
【Comprehensive Development Documentation】------ Full toolkit for R&D efficiency: Includes PC software, development manuals, and sample codes to minimize development time for diverse requirements, accelerating product deployment
Accelerometer parameters
|
Parameter
|
Condition
|
Typical value
|
|
Range
|
|
±16g
|
|
Resolution
|
±16g
|
0.0005g/LSB
|
|
RMS noise
|
Bandwidth = 100Hz
|
0.75~1mg-rms
|
|
Static zero drift
|
Horizontal placement
|
±20~40mg
|
|
Temperature drift
|
-40°C ~ +85°C
|
±0.15mg/℃
|
|
bandwidth
|
|
5~256Hz
|
|
Zero bias stability
|
10-second smoothing
|
XY: 15ug; Z: 35ug
|
|
Zero bias instability
|
allan variance
|
XY: 10ug; Z: 30ug
|
Gyroscope parameters
|
Parameter
|
Condition
|
Typical value
|
|
Range
|
|
±2000°/s
|
|
Resolution
|
±2000°/s
|
0.061(°/s)/(LSB)
|
|
RMS noise
|
Bandwidth = 100Hz
|
0.028~0.07(°/s)-rms
|
|
Static zero drift
|
Horizontal placement
|
±0.5~1°/s
|
|
Temperature drift
|
-40°C ~ +85°C
|
±0.005~0.015 (°/s)/℃
|
|
Bandwidth
|
|
5~256Hz
|
|
Zero bias stability
|
10-second smoothing
|
8°/h
|
|
Zero bias instability
|
allan variance
|
5°/h
|
Pitch and roll parameters
|
Parameter
|
Condition
|
Typical value
|
|
Range
|
|
X: ±180°; Y: ±90°
|
|
Tilt accuracy
|
|
0.2°
|
|
Resolution
|
Horizontal placement
|
0.0055°
|
|
Temperature drift
|
-40°C ~ +85°C
|
±0.5~1°
|
Heading angle parameters
|
Parameter
|
Condition
|
Typical value
|
|
Range
|
|
Z:±180°
|
|
Heading accuracy
|
Spin around
|
0.5° [1]
|
|
Resolution
|
Horizontal placement
|
0.0055°
|
Note:
[1] In some vibration environments, there will be cumulative errors. The specific error cannot be estimated and should be based on actual testing
Basic parameters
|
Parameter
|
Condition
|
Minimum value
|
Default
|
Maximum value
|
|
Communication interface
|
UART
|
4800bps
|
115200bps
|
230400bps
|
|
Output content
|
|
On-chip time, 3-axis acceleration, 3-axis angular velocity, 3-axis angle, quaternion
|
|
Sampling frequency
|
|
|
200Hz [1]
|
|
|
Operating temperature
|
|
-40℃
|
|
85℃
|
|
Storage temperature
|
|
-40 ℃
|
|
100 ℃
|
|
Impact resistance
|
|
|
|
20000g
|
Application
· Virtual reality/augmented reality, head-mounted displays
· Large-scale agricultural automatic farming
· Safety monitoring of high-altitude operations
· Drones, manned aircraft
· Industrial attitude monitoring
· Human motion tracking/capture
· Robots, autonomous guided transport vehicles
· Pedestrian navigation
· Unmanned driving/assisted driving